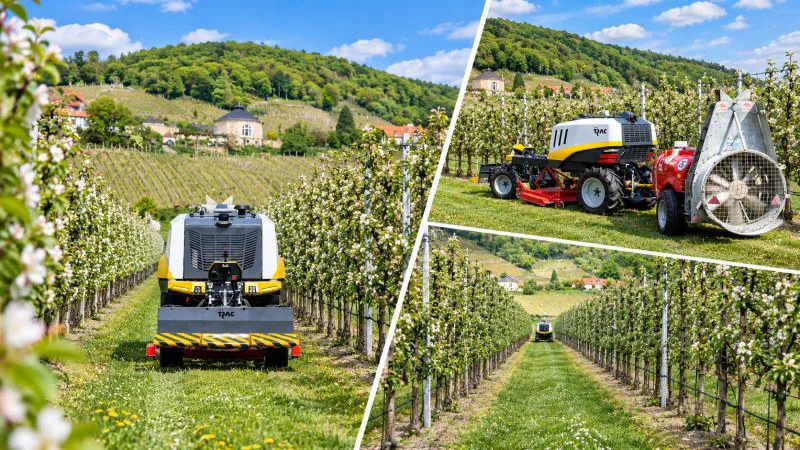
Together with strong partners, we are working in the KoSiNuS project to further develop innovative solutions for autonomous mobile machinery and bring them into practical application.
We are very pleased to continue to be part of this exciting project and to contribute our expertise at FusionSystems.
In the project, we are advancing in particular the vehicle environment perception of an agricultural machine. By processing and fusing data from various sensors, we create a robust foundation for reliable perception of the vehicle’s environment. In this way, we contribute to the further development of intelligent and autonomous mobility in various fields of application in Saxony.
We look forward to the next project phases, the continued exchange within the consortium, and many exciting insights on the shared path with Grünspecht Vision Labs, Hydrive Engineering GmbH, Fraunhofer IVI, SIListra Systems.
More on this topic: Automated Guided Vehicles and Mobile Machinery · Sensor Fusion & Physical AI
This post first appeared on LinkedIn. View the post on LinkedIn