Skip to content

Projects & References

Funded Projects

Our funded projects are financially supported by the German Federal Ministry of Education and Research (BMBF), the Federal Ministry for Economic Affairs and Energy (BMWi) and by the European Union and the European Regional Development Fund (ERDF).

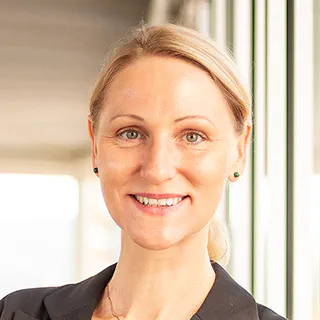
If you have any questions, please contact Ms Draeger, our project manager for funded R&D projects.

Photo: Jacqueline Draeger

Jacqueline Draeger

Project Manager, Funded R&D Projects

+49 371 83652521
Jacqueline.Draeger@fusionsystems.de

Current funded projects

KoSiNuS

The overall goal of the “KoSiNuS” project is the development of central components and safety architectures for use in autonomous mobile machinery and systems.

For the subsystems required in the control architecture of autonomous mobile machinery, there are currently hardly any suppliers, because these subsystems require cutting-edge technologies that at present exist mainly as concepts in science, as inaccessible solutions at large internet corporations or as specific components in the automotive industry. The transferability, accessibility and economic viability of such solutions for the field of mobile machinery is therefore often not given. This applies above all to environment perception with person, free-space and obstacle detection that can potentially be relied on for safety, to image processing hardware that can potentially be relied on for safety and is also, and especially, suitable for dusty and vibration-intensive environments, to computing hardware that can potentially be relied on for safety and can be used for different computing power requirements with reasonable development effort, and to autonomy control software that is modular and adaptable to the respective application.

In addition, there are currently no binding regulatory frameworks and standards for the fully automated operation of agricultural and construction machinery. Accordingly, there is currently also no consensus on safety concepts and their validation for specific use cases. As a result, robot manufacturers and potential suppliers of the components mentioned above lack reliable requirements for their safety design.

A key challenge is the use of machine learning (ML) and artificial intelligence (AI) for environment perception. On the one hand, this offers potentially high detection performance; on the other hand, it poses major challenges for all of the aspects mentioned above.

These topics are addressed in the project.
Co-funded by the European Union Free State of Saxony: This measure is co-financed with tax funds on the basis of the budget passed by the Saxon State Parliament.

InnoTeam RoSa

Despite technological progress, there are still considerable challenges in the application of robots. These include the real-time processing of large volumes of 3D data, the modelling of the robots, necessary path adjustments and the complex integration of sensors and models into robot systems.
The InnoTeam RoSa combines basic technologies from research with industrial requirements. In cooperation with partners, technologies for various use cases are analysed in order to research methods and algorithms for software modules for robot systems, with combinability and interfaces being taken into account from the outset. The methods and algorithms developed from this are tailored to the use cases and implemented generically in order to ensure the connection to the Robot Operating System (ROS) and compatibility with VDA 5050. Test setups for validation are built in the laboratory, with the goal of implementing at least one use case as a prototype in the participating companies. All activities are integrated into a methodology for the efficient introduction of robot applications. The research needs of the companies go beyond the state of the art and require interdisciplinary approaches.

The project partners are Flender Industriegetriebe GmbH, H+E Produktentwicklung GmbH, MW Robotics Germany GmbH, the Fraunhofer Institute for Machine Tools and Forming Technology (IWU) Dresden and Chemnitz University of Technology with the Institute for Machine Tools and Production Processes (IWP) and the Professorship of Production Systems and Processes (PSP).

Co-funded by the European Union Free State of Saxony: This measure is co-financed with tax funds on the basis of the budget passed by the Saxon State Parliament.

Automated Parking Garage

The goal of the parking garage project Future Parking is to optimise the use of parking and logistics areas inside buildings by using innovative technologies. For example, the areas there are equipped with positioning and information technology, so that dynamic localisation of objects and vehicles enables efficient parking garage management. For the operators and users of the parking and logistics areas, an app is being developed as the interface between the parties involved and the background system of the parking garage control.

The project partners are: the Institute of Traffic Telematics at TU Dresden, glts cotech GmbH, Metirionic GmbH and Dresden elektronik verkehrstechnik gmbh.

Visit the project website at future-parking.de

European Union. Europe funds Saxony. ERDF – European Regional Development Fund SAB – Sächsische Aufbaubank

diVIBES

The goal of the project is to make a significant contribution to improving predictive condition monitoring and process optimisation by means of vibration measurement in an extended frequency range, using new approaches in sensor technology as well as in the acquisition, processing, networking and use of machine learning (ML) methods. The Reference Architecture Model Industrie 4.0 (RAMI 4.0) is to be chosen as the basic structure for the implementation, so that further Industrie 4.0 participants can also be integrated into the overall system to be developed in the future. FusionSystems will focus in particular on evaluating the decentrally preprocessed sensor data with AI methods and thus enabling automatable monitoring of plants on the basis of their intelligently assessed vibration characteristics. For this purpose, the widely used IoT protocols MQTT and OPC UA are chosen as the approach for evaluating the data in a cloud-based manner (database system). To ensure this, data preprocessing close to the sensor is necessary.

The project partners are: Electronic Design Chemnitz GmbH (Chemnitz), X-FAB MEMS Foundry GmbH (Erfurt), SPEKTRA Schwingungstechnik und Akustik GmbH (Dresden), the Fraunhofer Institute for Electronic Nano Systems (Chemnitz) and TU Chemnitz, Center for Microtechnologies (Chemnitz).

Funded by the Federal Ministry of Education and Research

eaasySystem

The subproject “EaasySystem-Umfeldwahrnehmung” (EaasySystem environment perception) is an essential part of the development and testing of the autonomous driving function of the EaasySystem in urban areas. In the project, FusionSystems GmbH develops the sensor concept and the software modules for environment perception, in particular in the area of bicycle and pedestrian infrastructure, with a focus on the sensor-based perception of the specific delivery person, of other persons and of obstacles in the driving corridor as well as on the reliable classification of the freely drivable corridor. The local dynamic map of the vehicle environment that is finally made available forms the basis for the implementation of the come-with-me function, the path and trajectory planning and the control of the overall system by the project partners.

The cooperation partners are: Marketing Service Magdeburg GmbH, ONOMOTION GmbH 12435 Berlin, Institut für Automatisierung und Informatik GmbH 38855 Wernigerode and Otto von Guericke University 39106 Magdeburg, Germany

Supported by: Federal Ministry for Economic Affairs and Energy on the basis of a decision by the German Bundestag

HMI4Rail

The subproject “Vitalsensordatenfusion” (vital sensor data fusion) is part of the overall project HMI4Rail. The goals of the subproject focus on the development of a system for the time-synchronised recording and storage of measurement data from different sensors. The system must be usable both in the laboratory environment and in field tests. A further requirement for the system is to visualise the recorded data afterwards and to make it available for further processing. The system should also be able to carry out a data conversion where necessary in order to enable data evaluation with external software. As part of the subproject, initial data analyses are carried out and implemented together with the project partners. In particular, the most promising methods for pattern recognition and classification are to be worked out.

The cooperation partners are: TU Chemnitz (TUC), German Aerospace Center (DLR), Saralon (SAR), Core Mountains (CoM), Sieber Sport Strumpffabrik (SiT), Smart Rail Connectivity Campus gGmbH (SRCC)

Supported by: Federal Ministry of Research, Technology and Space

HZwo:FRAME

The central topic of HZwo:FRAME is new processes for the large-scale series production of metallic bipolar plates. The goal of the project is to make a core contribution to research in process and product development for low-cost metallic bipolar plates that can be manufactured in large-scale series. FusionSystems is to co-develop a quality inspection for fuel cells across the entire manufacturing process. In addition, the use of image processing is to make it easier to capture and evaluate various other data.

The project partners are: Continental Automotive GmbH, Von Ardenne GmbH, miTec – Microtechnologie GmbH, LASERVORM GmbH, Chemnitz University of Technology and Steinbeis Innovation gGmbH

European Union. Europe funds Saxony. ERDF – European Regional Development Fund SAB – Sächsische Aufbaubank

MiRobO

In the future, service robots will not be passive recipients of commands but will act as active dialogue partners when handing over objects. In this project, multimodal interaction strategies are developed that serve the handover of objects by service robots to people with or without eye contact (e.g. due to impaired vision). In addition, this safe handover is to be used for objects that are visibly or invisibly dangerous.

The project partners are: SIKOM Software GmbH, designaffairs GmbH, Fraunhofer IWU and the Professorship of Ergonomics and Innovation Management at TU Chemnitz.

Funded by the Federal Ministry of Education and Research

OPTmicro

Intelligent, automated and autonomous micromobility vehicles can reduce CO2 emissions and traffic. Because developments to date have been strongly geared towards the automobile, there is currently no open dataset for developing and testing, for example, algorithms for object detection or trajectory prediction for automated driving away from motor vehicle roadways. The OPTmicro project has set itself the goal of providing such a dataset as an open data application in order to enable developers of mobility solutions to train AI/ML applications at an early stage. The aim is to provide a classification that is as fine-grained as possible through diverse object types in different traffic situations, weather conditions, times of day and seasons.

The cooperation partner is: Merseburg University of Applied Sciences

We make the project results available here.

Sensor concept and data acquisition (PDF, in German)

OPTmicro Labeling Guide (PDF)

Python script for visualisation (ZIP)

OPTmicro test dataset (ZIP)

The complete dataset can be made available on request. Please contact info@fusionsystems.de .

Federal Ministry for Digital and Transport mFUND

RADimFOKUS

In times of automated vehicles, warning and safety concepts are important to ensure safety for all other modes of transport such as cyclists, buses and trains as well as cars. This is where the funded project RADimFokus comes in, which is to research and realise as a prototype a cross-modal warning and assistance system for cyclists. The designed warning and assistance system allows warnings not only in acutely dangerous situations but also in predictive form.

The project partners are: Fraunhofer IVI, KOMSA AG, Chemnitz University of Technology, Binova GmbH, dresden elektronik ingenieurtechnik gmbh.

European Union. Europe funds Saxony. ERDF – European Regional Development Fund SAB – Sächsische Aufbaubank

smarTram

In aerospace, in the automotive industry and also in rail transport, work on autonomous driving has been under way for years. It has already been fully implemented in some subways and segregated metro lines. With increased interaction with other road users, as on the road or with trams, however, current systems usually reach their limits. For this reason, the planned project works out and improves technical solutions for using automation potential in the tram sector. The practical validation of the technologies is carried out with the help of a tram and the operating environment of Chemnitzer Verkehrs-AG.

The cooperation partners are: Hörmann Vehicle Engineering GmbH 09112 Chemnitz, IABG GmbH 85521 Ottobrunn and Chemnitzer Verkehrs AG 09127 Chemnitz

Supported by: Federal Ministry for Economic Affairs and Climate Action on the basis of a decision by the German Bundestag

TADA crossroad

Under the title “AMZ Sachsen: TADA_Crossroad – Forschung und Entwicklung von intelligenter Verkehrsinfrastruktur für den Innenstadtbereich – Teilvorhaben C” (research and development of intelligent traffic infrastructure for inner-city areas – subproject C), intelligent traffic infrastructures for inner-city areas are to be researched and developed. It should be possible, in connected intersection situations, to detect the expected routes of connected and non-connected road users (motor vehicles, bicycles, pedestrians) and to fuse them into an integrated model of the current and expected traffic situation in the study area. The goal of the project is to prove the functional principle under laboratory conditions and in the simulation of various scenarios and disturbance factors typical of intersection situations.

The project partners are: RKW Sachsen Rationalisierungs- und Innovationszentrum e. V. (Dresden), Dresden Elektronik Ingenieurtechnik GmbH (Dresden), NAVENTIK GmbH (Chemnitz), Trillium Secure Inc. (USA) and Derq Inc. (USA)

Funded by the Federal Ministry of Education and Research

TADA Sweeper

Under the title “AMZ Sachsen: TADA_Sweeper – Entwicklung und Validierung einer Technologie zu einer autonom fahrenden und automatisiert reinigenden Kehrmaschine (Technologieträger) über 12 Tonnen – Teilvorhaben C” (development and validation of a technology for an autonomously driving and automatically cleaning street sweeper (technology demonstrator) over 12 tons – subproject C), an autonomously driving street sweeper that automatically cleans the street space is to be developed jointly in this project. Powerful sensor and intelligence solutions are to be developed that are integrated into a standard street sweeper and enable comprehensive environment perception as well as situation-dependent independent decision-making in the event of unexpected disturbances and obstacles. In the USA, an integrated, powerful security system is also being developed to prevent unauthorised access to the machine.

The project partners are: RKW Sachsen Rationalisierungs- und Innovationszentrum e. V. (Dresden), FAUN Viatec GmbH (Grimma), NAVENTIK GmbH (Chemnitz), New Eagle (USA) and Trillium Secure Inc. (USA)

Funded by the Federal Ministry of Education and Research

Wahrnehmungsnetz (Perception Network)

The goal of the project is to implement a real-time-capable perception network at urban traffic junctions through the decentralised fusion of the environment perception of intelligent vehicles with the environment perception of intelligent traffic infrastructure. Three innovations are implemented in the joint project: (a) real-time-capable common operational pictures of complex traffic junctions through (b) decentralised data fusion in a (c) dynamic perception network that grows with demand.

The project partners are: Chemnitz University of Technology, Valeo Auto-electric Wischer und Motoren GmbH

Federal Ministry of Transport and Digital Infrastructure

Werkzeugentstehungsprozess (Tool Creation Process)

The goal of the joint research project is to develop a method for an automated tool tryout process for primary forming and forming tools in the tool creation process. A further key focus with regard to automating the tryout process is the digitisation of the contact pattern. The focus here is particularly on the spotted sheets produced during the trial pressing. By automating this process, machines can evaluate the colour changes by means of image processing and AI.

The project partners are: Pockauer Werkzeugbau Oertel GmbH, Werkzeugbau Winkelmühle GmbH, DIT Diamanttechnik GmbH & Co. KG, SN Spindeltechnik GmbH, Fraunhofer Institute for Machine Tools and Forming Technology (IWU)

European Union. Europe funds Saxony. ERDF – European Regional Development Fund SAB – Sächsische Aufbaubank