AI Services
AI Development
We develop the methods that turn your data into reliable results: machine learning, AI pipelines, agents, multimodal analysis, and hybrid models.
Solutions
Multi-sensor environment perception for machines that move on their own: automated guided vehicles on the shop floor, mobile robots in manufacturing, and mobile machinery in the field.
Manufacturers and operators of automated guided vehicles, mobile robots, agricultural and construction machinery, and companies that automate their material flow.
We deliver environment perception and navigation as a software component for your vehicles and machines and integrate them into your controller and your control level. We take the industry’s interfaces, the Robot Operating System (ROS) and VDA 5050, into account from the start.
Whether it is a transport vehicle on the shop floor, a mobile robot in manufacturing, or mobile machinery in the field: a machine that moves on its own must perceive its environment reliably. That has been our field of expertise since the company was founded. To achieve this, FusionSystems combines multiple sensors into one picture of the environment and derives from it where the machine is, what is happening around it, and where it can drive safely.
No single sensor sees everything. A camera recognises what an object is, a laser scanner measures precisely how far away it is, and additional sensors provide motion and orientation. Multi-sensor environment perception brings these data together. The result is an environment model that contains people, objects, obstacles, and drivable free space and that holds up even with dust, backlight, or vibrations.
We use the same foundation in road traffic, on the shop floor, and in the field. We describe the methods under Sensor Fusion & Physical AI and the detection of people under Person Detection.
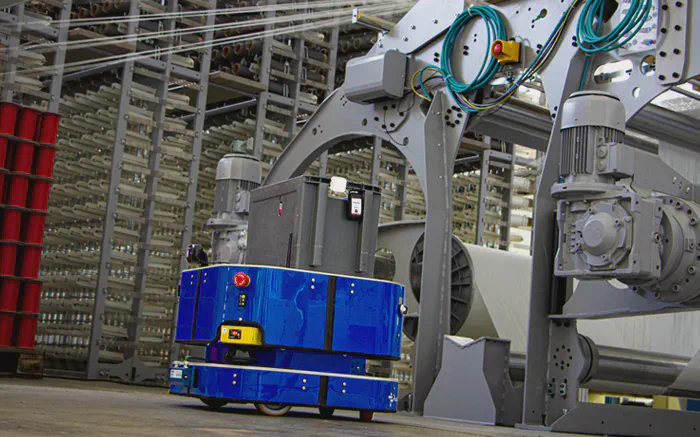
MULI is the automated guided vehicle from FusionSystems. We conceived, designed, and developed it ourselves. Its modular structure allows it to be adapted to different tasks; it navigates indoors and outdoors. Software and sensors for person, object, and obstacle detection ensure safe operation in production, logistics, and transport.
An automated guided vehicle makes the material flow flexible: it transports small load carriers between warehouse, machine, and assembly and replaces rigid conveyor technology. We integrate it into the control level through our control and visualisation system.
In the funded project InnoTeam RoSa, we are developing MULI further. The project combines the mobile platform with an articulated robot arm: the robot comes to the workpiece instead of the workpiece being brought to the robot. For this, the system must capture its environment in three dimensions, know its own position precisely, and coordinate the motion of platform and arm. Our environment perception provides the foundation for this.
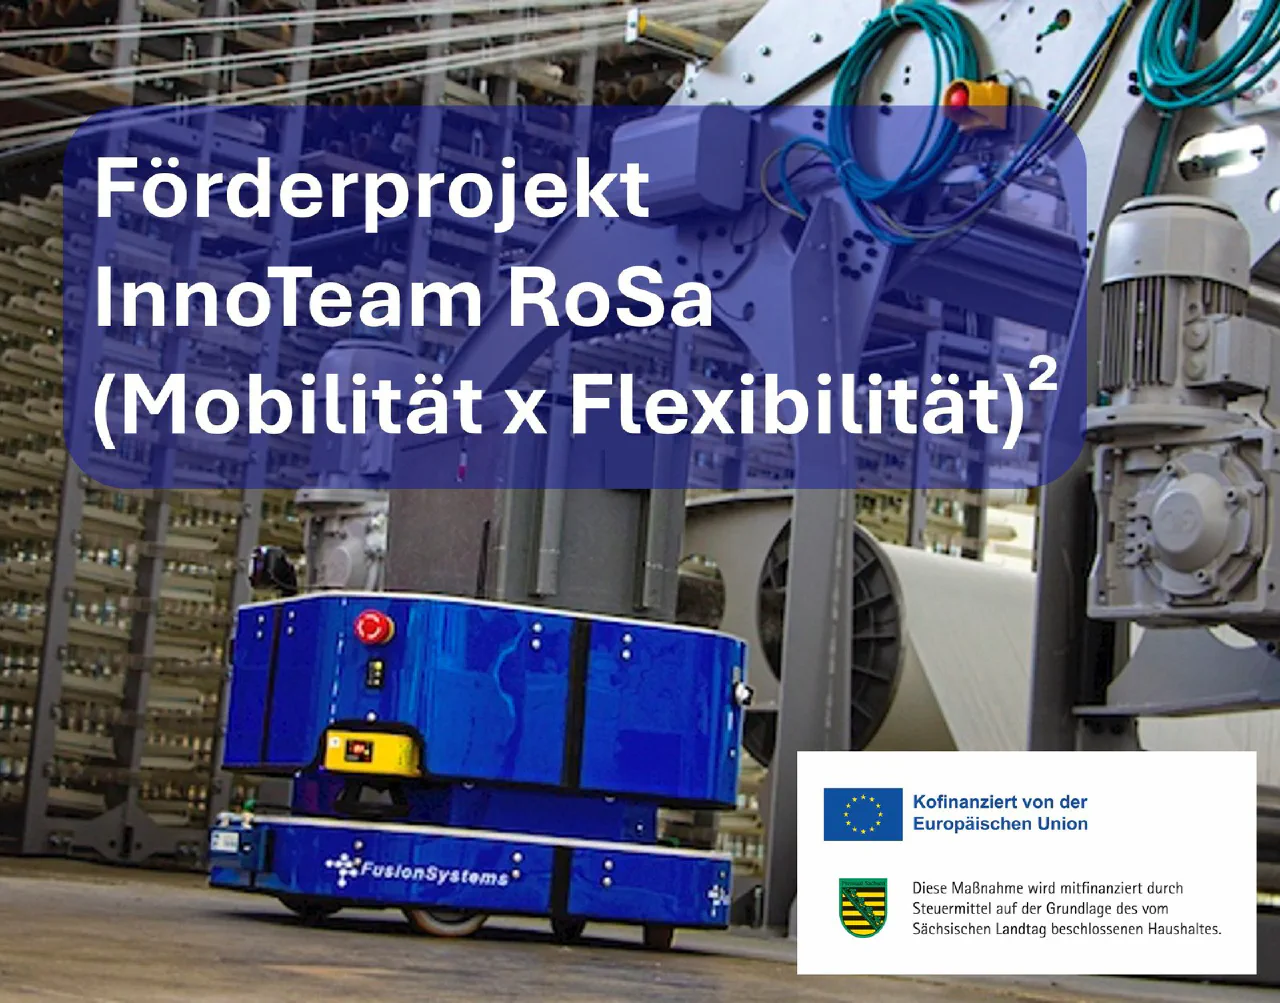
More about the project is available under Funded Projects.
What applies on the shop floor also applies outdoors. In the KoSiNuS project, we are equipping an agricultural machine with vehicle environment perception. We process and fuse the data from various sensors so that the machine reliably detects people, obstacles, and a clear travel path, between rows of plants as well as at the edge of the field. The project develops central components and safety architectures for autonomous mobile machinery.
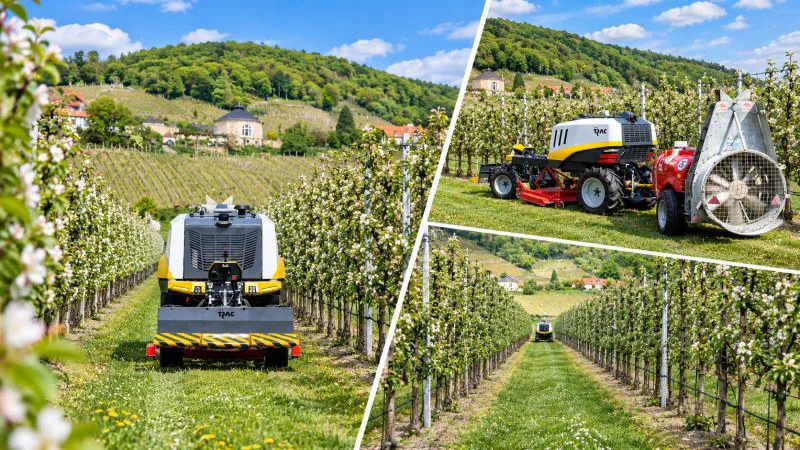
Learn more in the FusionBLOG and under Funded Projects.
A mobile machine must know where it is at all times. We use several types of navigation for this and combine them into hybrid navigation:
The combination increases efficiency, flexibility, and safety. We set up the sensors for your environment.
FusionSystems contributes its experience to the professional community. Dr.-Ing. Ullrich Scheunert and Axel Pätzold are active members of the VDI technical committee “Autonomous Mobile Robotics”. FusionSystems is a member of the industry association Forum-FTS.
We describe the application in manufacturing under Manufacturing and Mechanical Engineering and environment perception in road traffic under Environment Perception for Autonomous Public Transport.
AI Services
We develop the methods that turn your data into reliable results: machine learning, AI pipelines, agents, multimodal analysis, and hybrid models.
AI Services
AI becomes usable where the work is done: as a function in existing software, as an interface, or as a separate application in your system landscape.
AI Technologies
Combining information from different physical measurement sources – camera, radar, LiDAR, and other sensors – as the basis for systems that act in the real world.
AI Technologies
Image-based and video-based AI, grown out of many years of experience in industrial machine vision.
Solutions
Detecting, tracking, and understanding people in camera images: position, motion, posture, gestures, and face – with high detection performance and a low false alarm rate.
Industries
Preserve experience-based knowledge, manage variants, and use image and sensor data to assess condition and quality.
Industries
Environment perception, sensor data fusion and digital environment models, plus AI support for the software engineering process.
Projects & References
Perception in the vehicle and the digital environment model of the operating area work hand in hand: what the vehicle detects becomes permanently usable knowledge about the environment.
Whether a first AI adoption or a complex development task – we discuss the requirements and suitable next steps with you.